Wayno Autonomous Robot Car
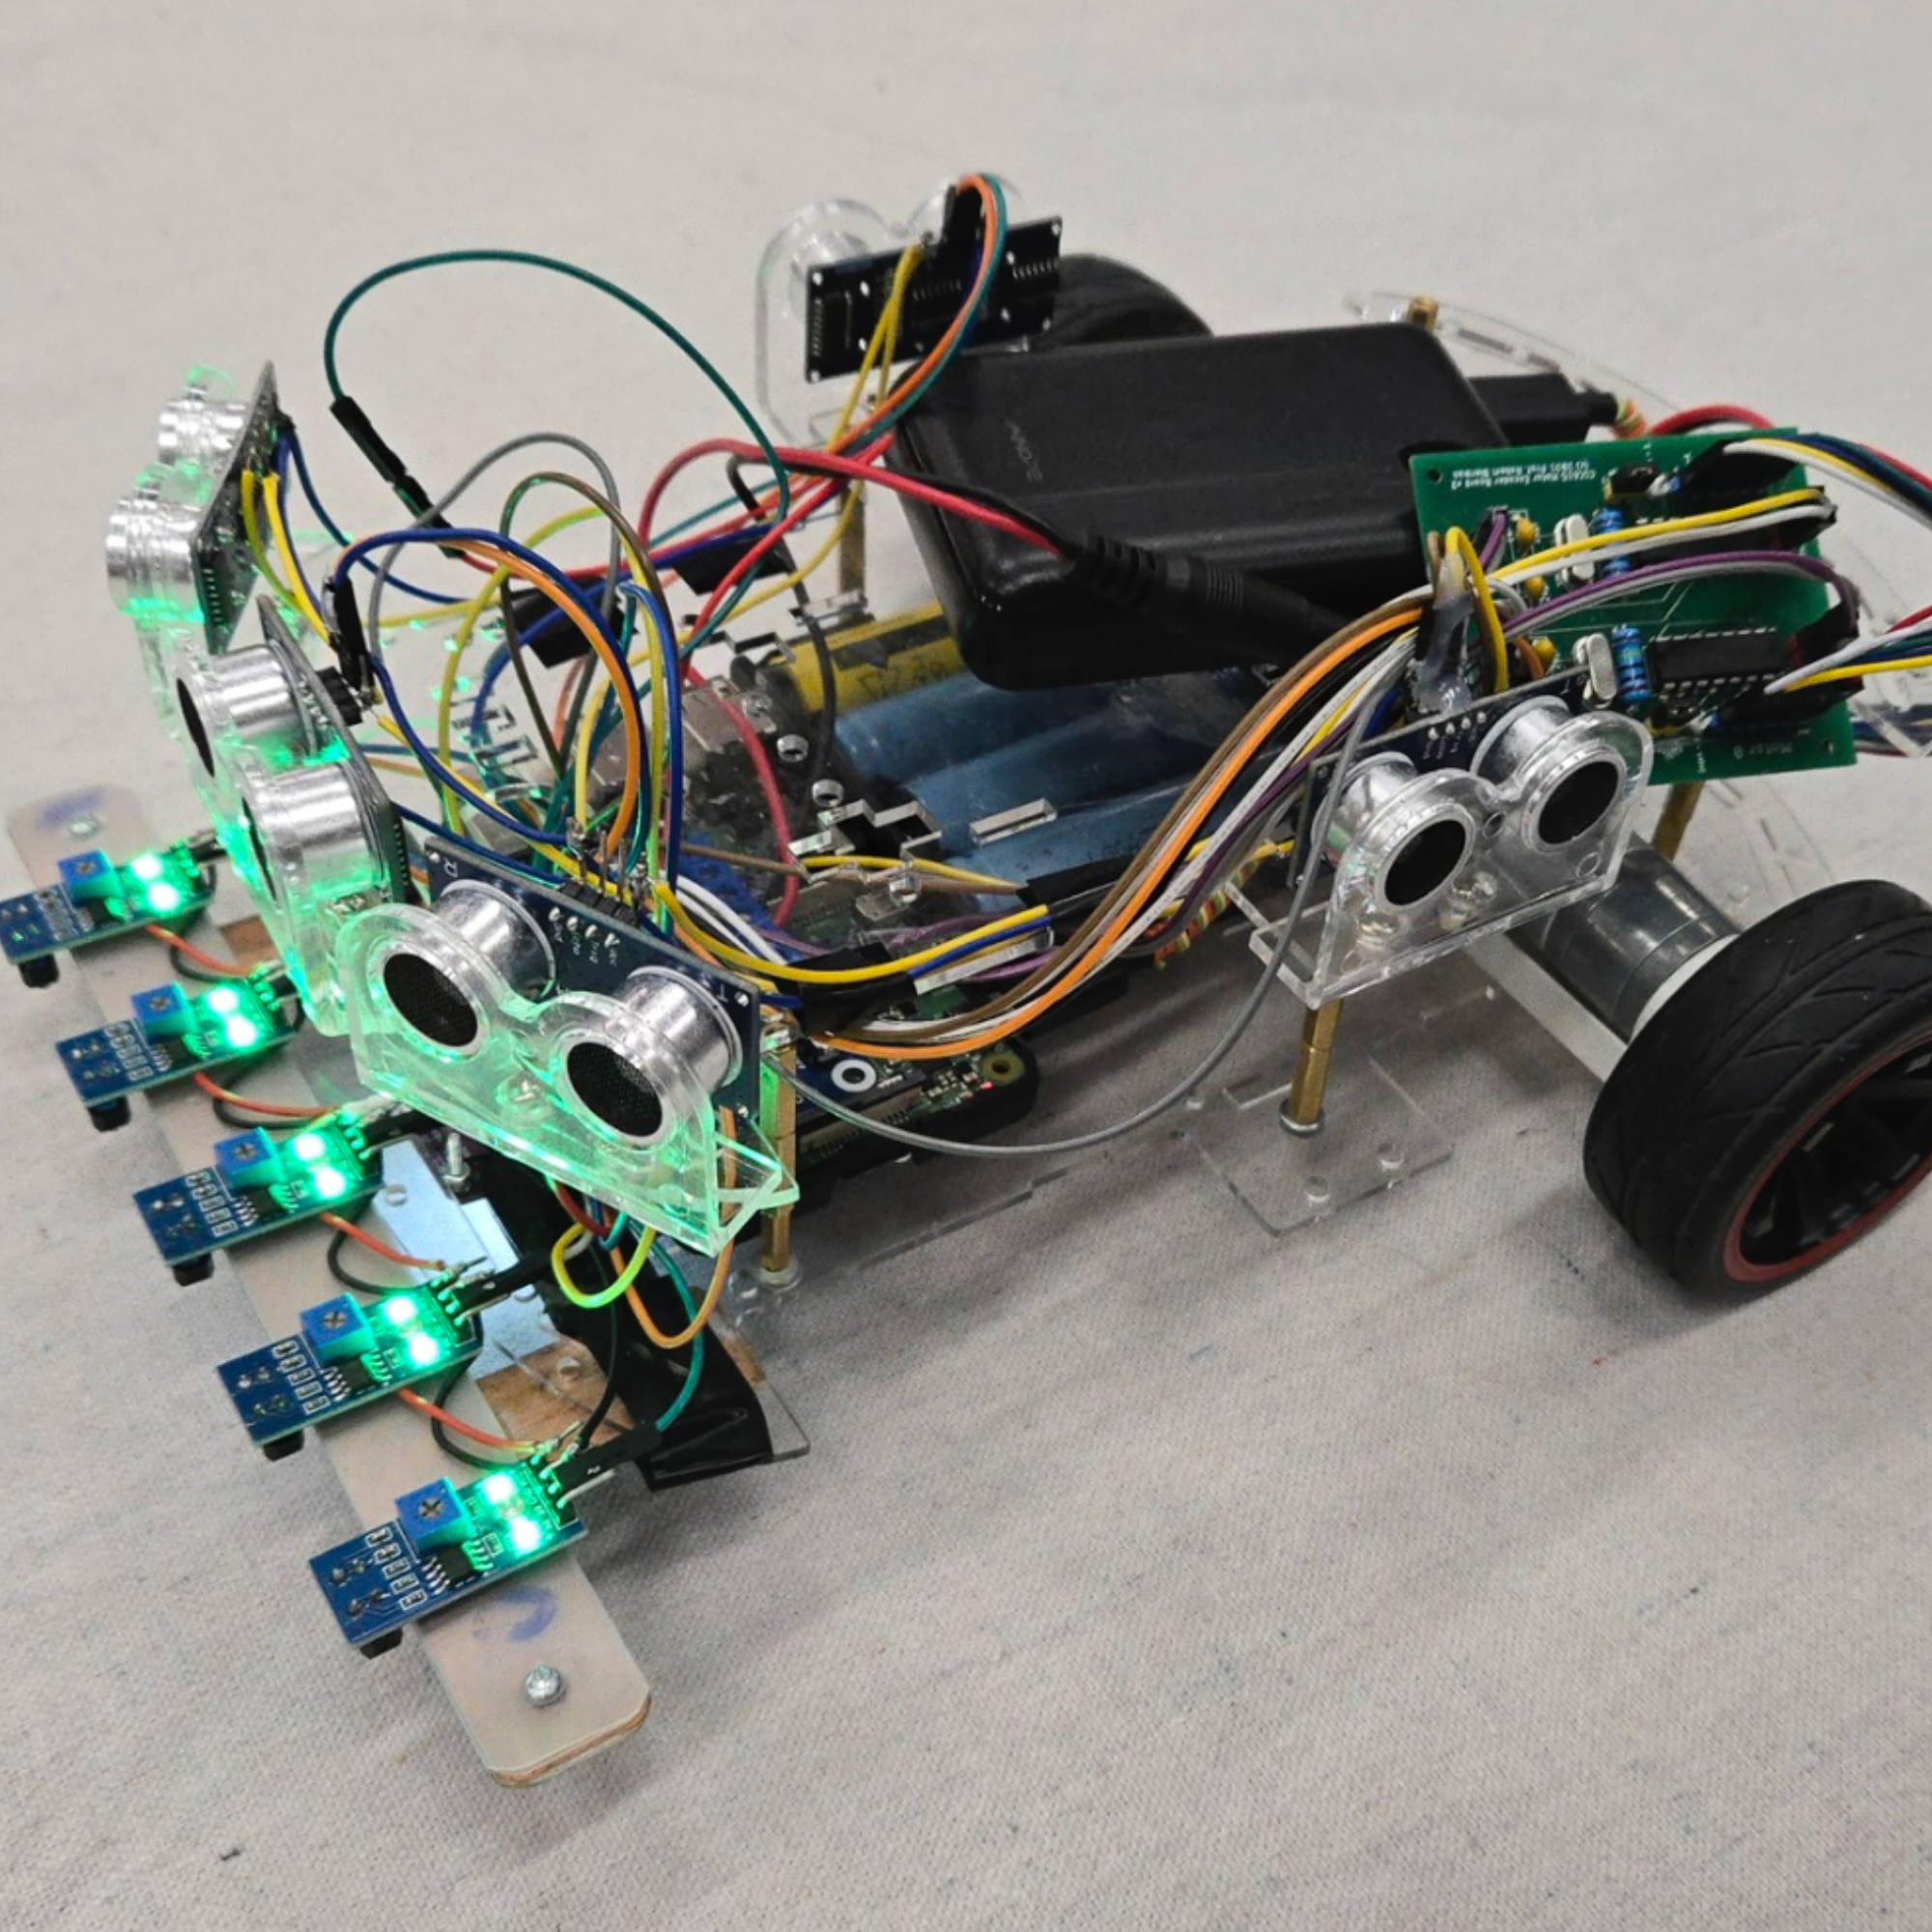
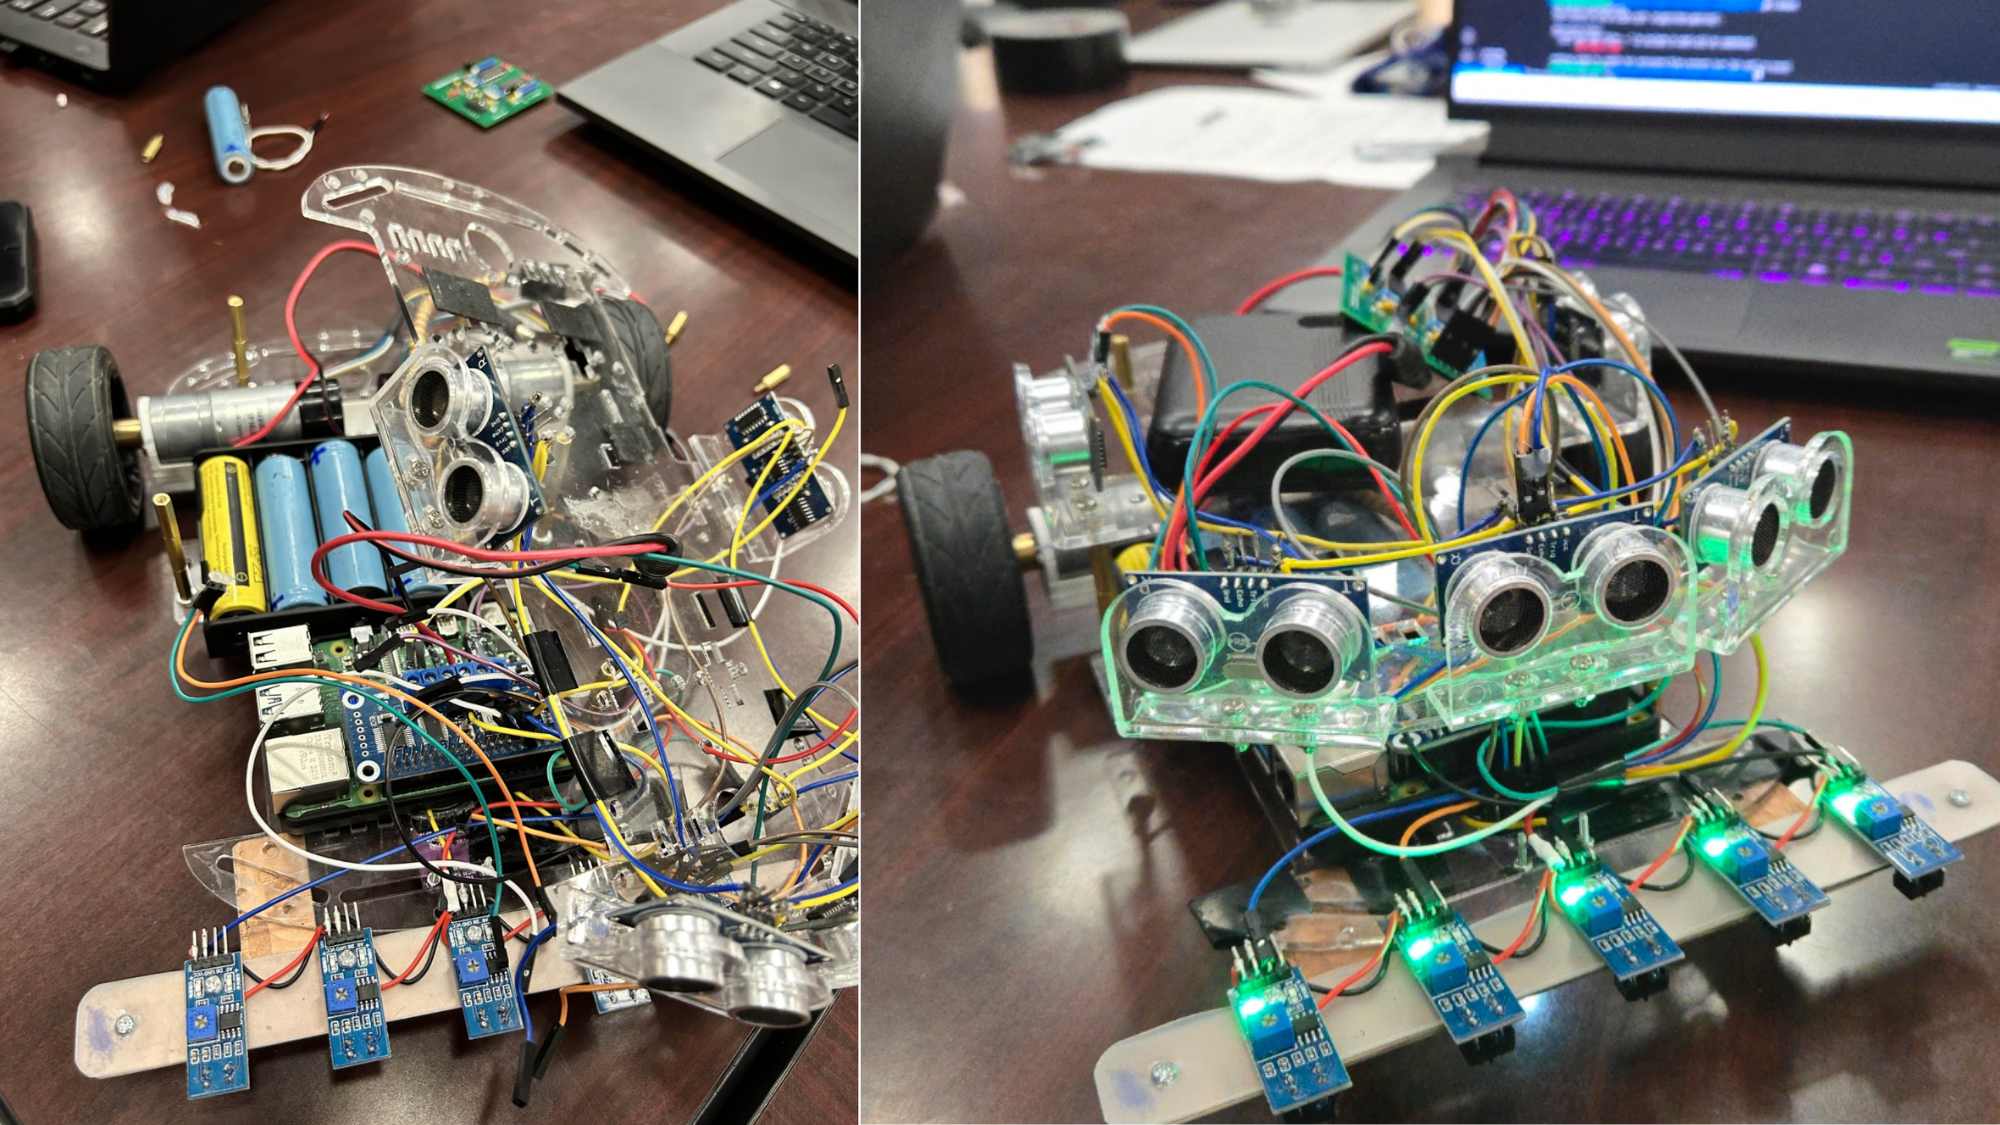
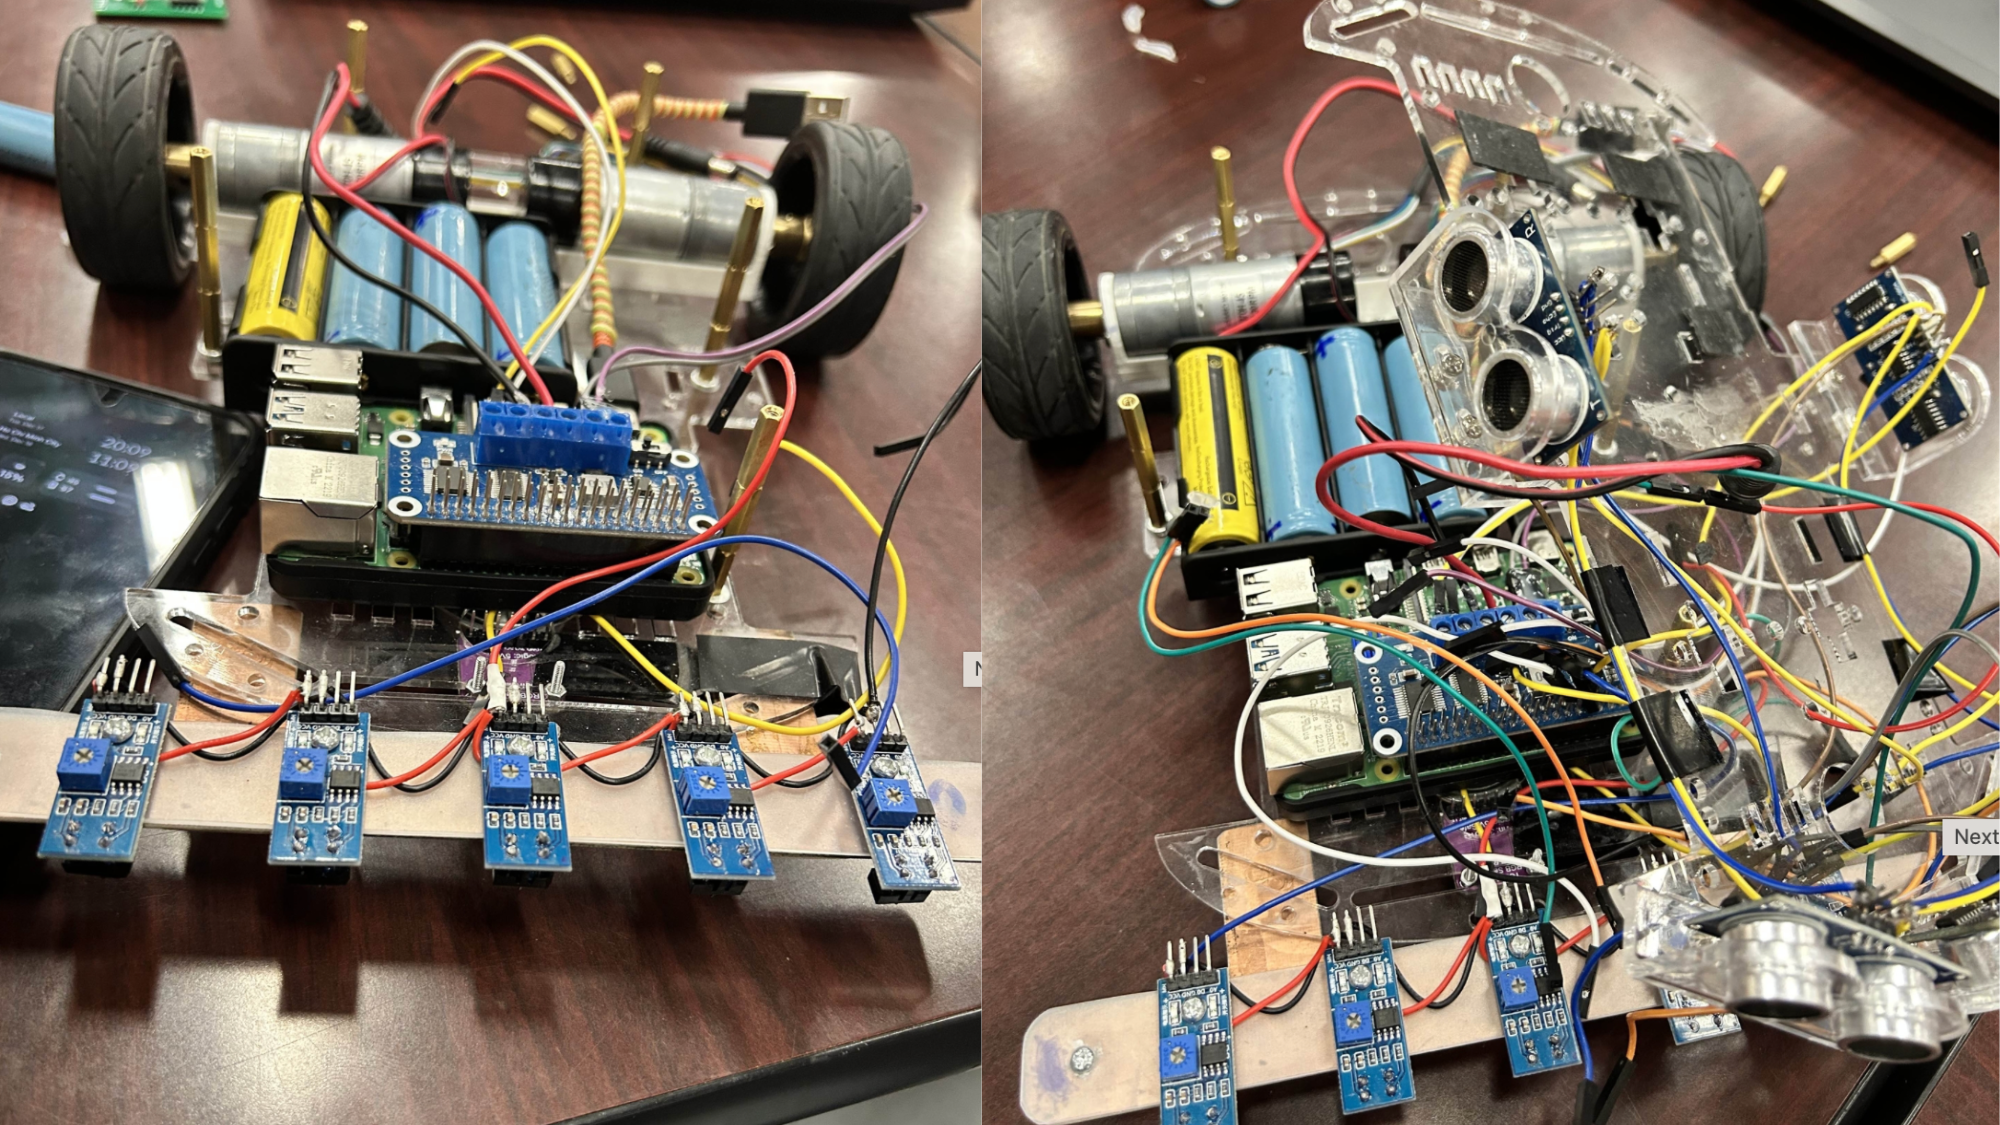
An Embedded Linux term project focused on building an autonomous robot car powered by a Raspberry Pi 4. The vehicle combines line-following functionality with obstacle detection and avoidance using ultrasonic sensors, and was designed to stop when an RGB sensor detected a red line. The system integrates PID control for precision line-tracking, multi-sensor fusion for navigation, and efficient motor control through encoders and a motor HAT. This project highlights embedded systems design, low-level programming in C, hardware-software integration, and real-time robotics problem-solving.
Project Features
Line Following with PID
Implemented PID algorithm with five line sensors for accurate line tracking and smooth turns.
Obstacle Detection & Avoidance
Integrated HC-SR04 ultrasonic sensors (front, left, right) to detect obstacles and perform avoidance maneuvers.
Power & Motor Control
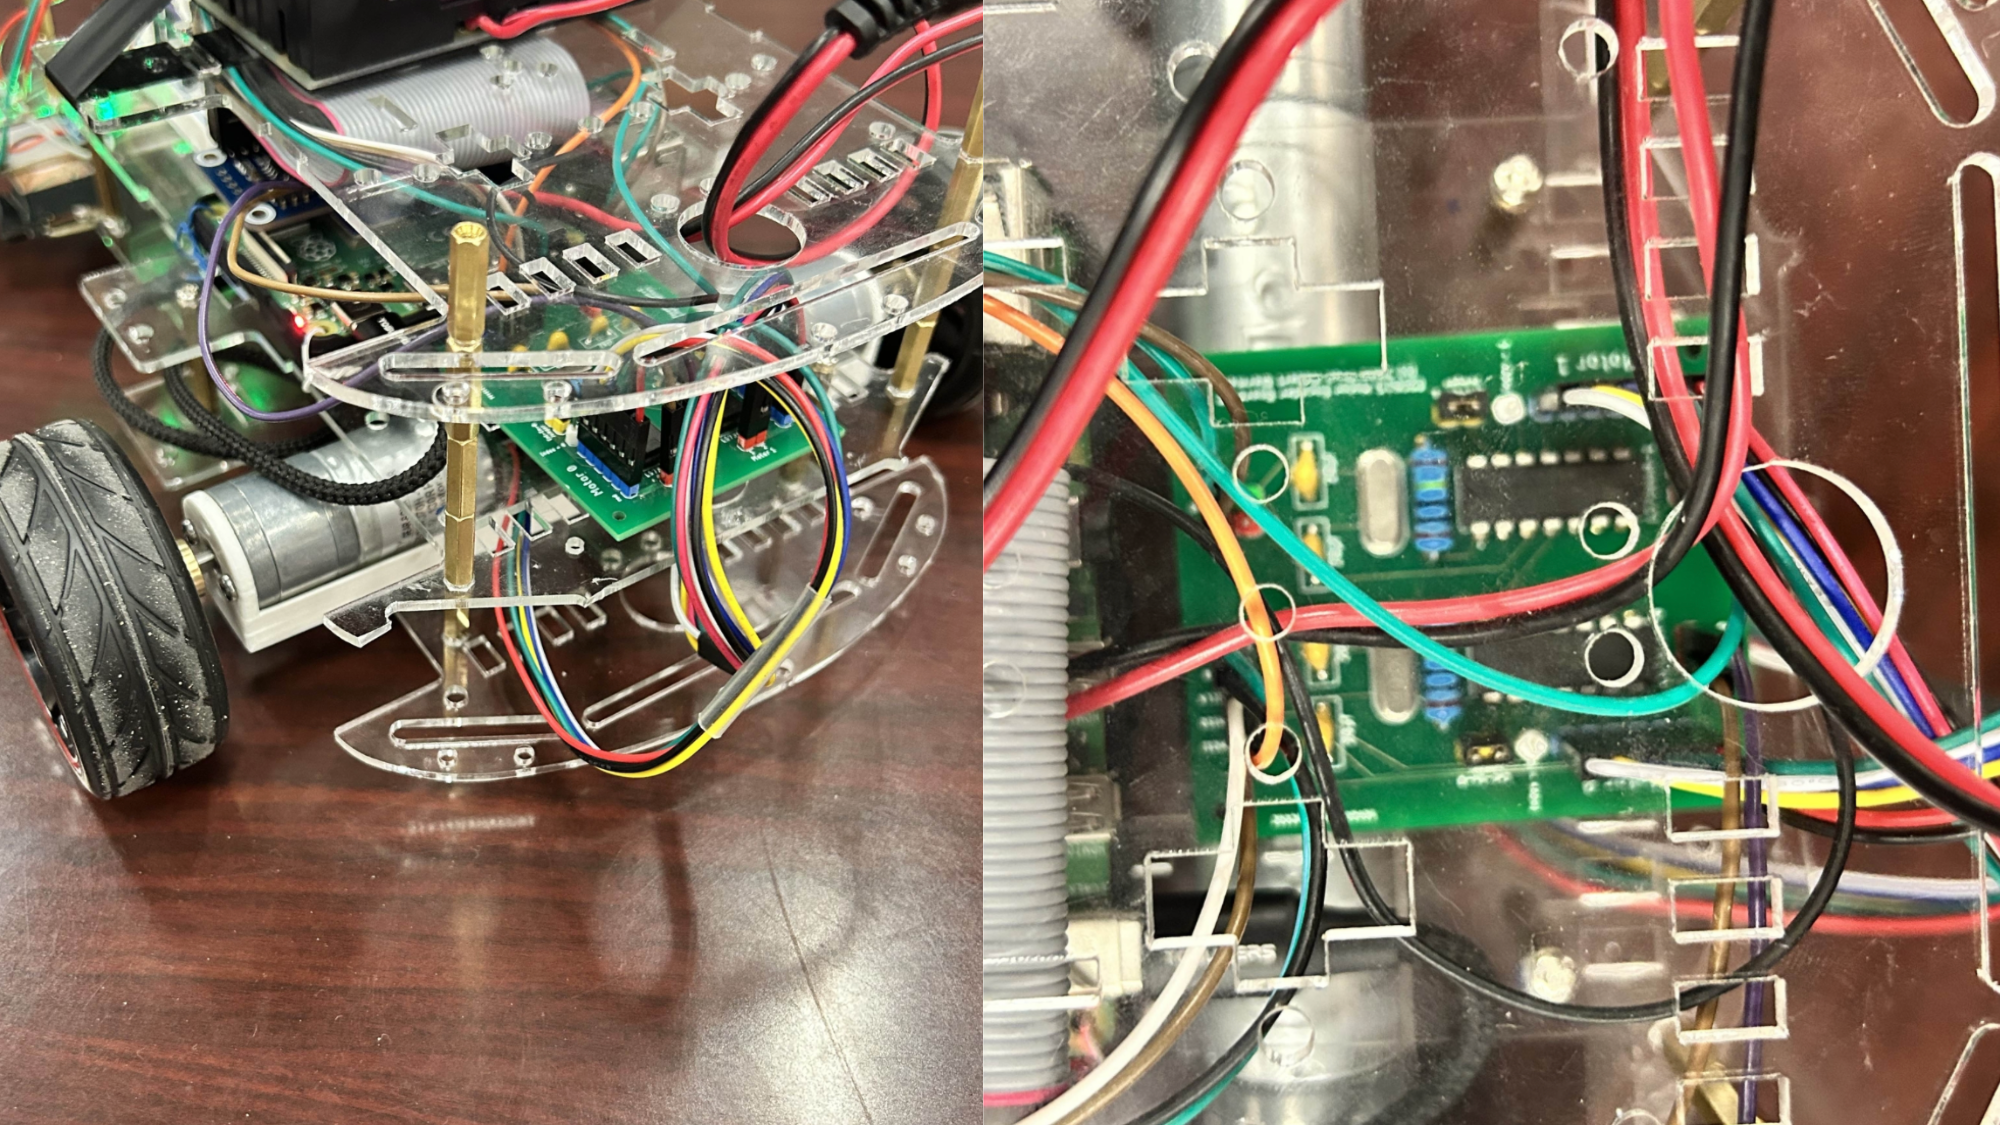
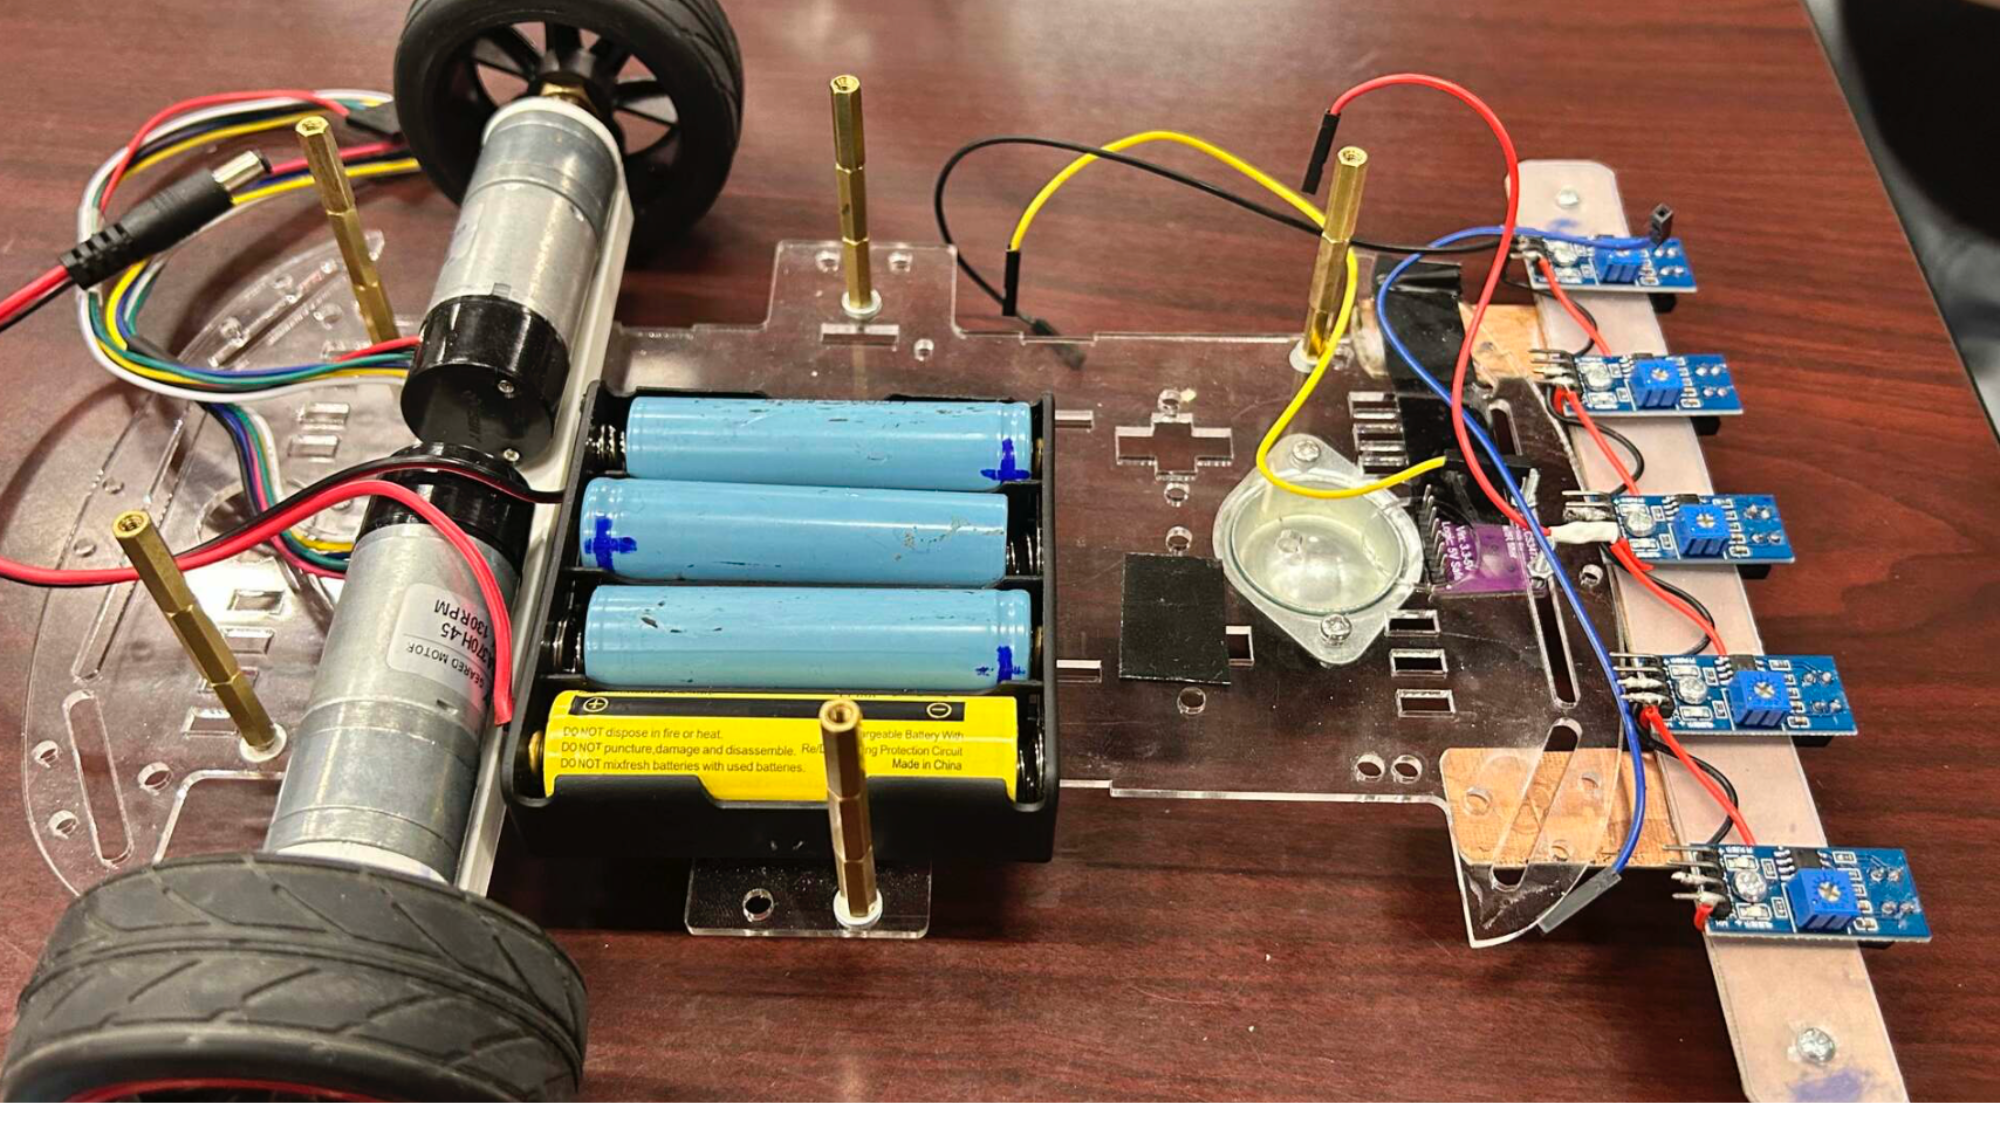
Used 18650 batteries for motors and a dedicated power bank for the Raspberry Pi, with WaveShare Motor HAT for control.
Hardware-Software Integration
Combined Raspberry Pi GPIO programming, motor encoders, line sensors, and ultrasonic sensors in C with embedded Linux.
Project Info
08/2024 – 10/2024
Embedded Systems Developer
4 Members
Completed
Technologies Used
- • Raspberry Pi 4 (Main Controller)
- • TS-25GA370H-45 Motors with Encoders
- • HC-SR04 Ultrasonic Sensors
- • TCRT5000 Line Sensors
- • TCS34725 RGB Color Sensor (attempted)
- • WaveShare Motor HAT
- • C (bcm2835, pigpio, standard C libraries)
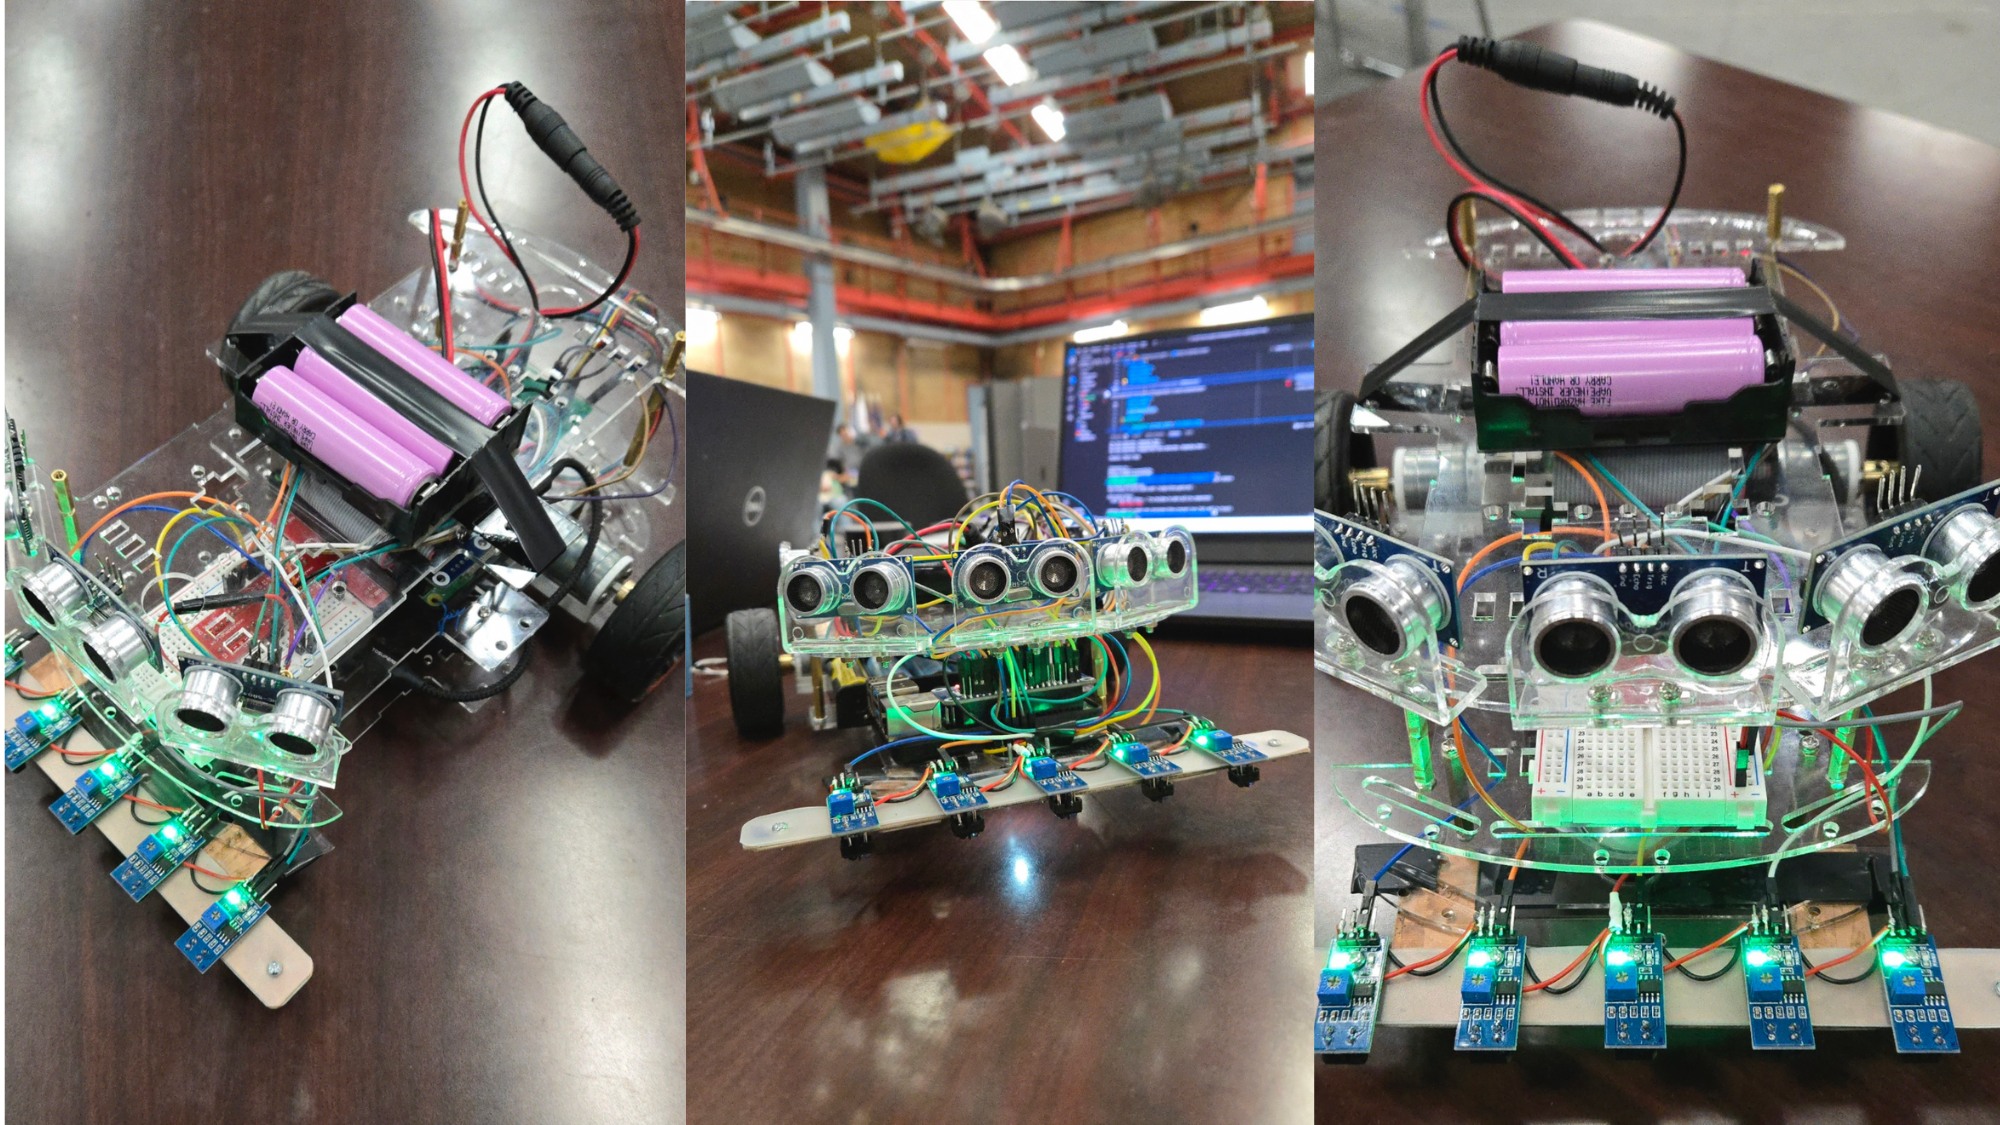
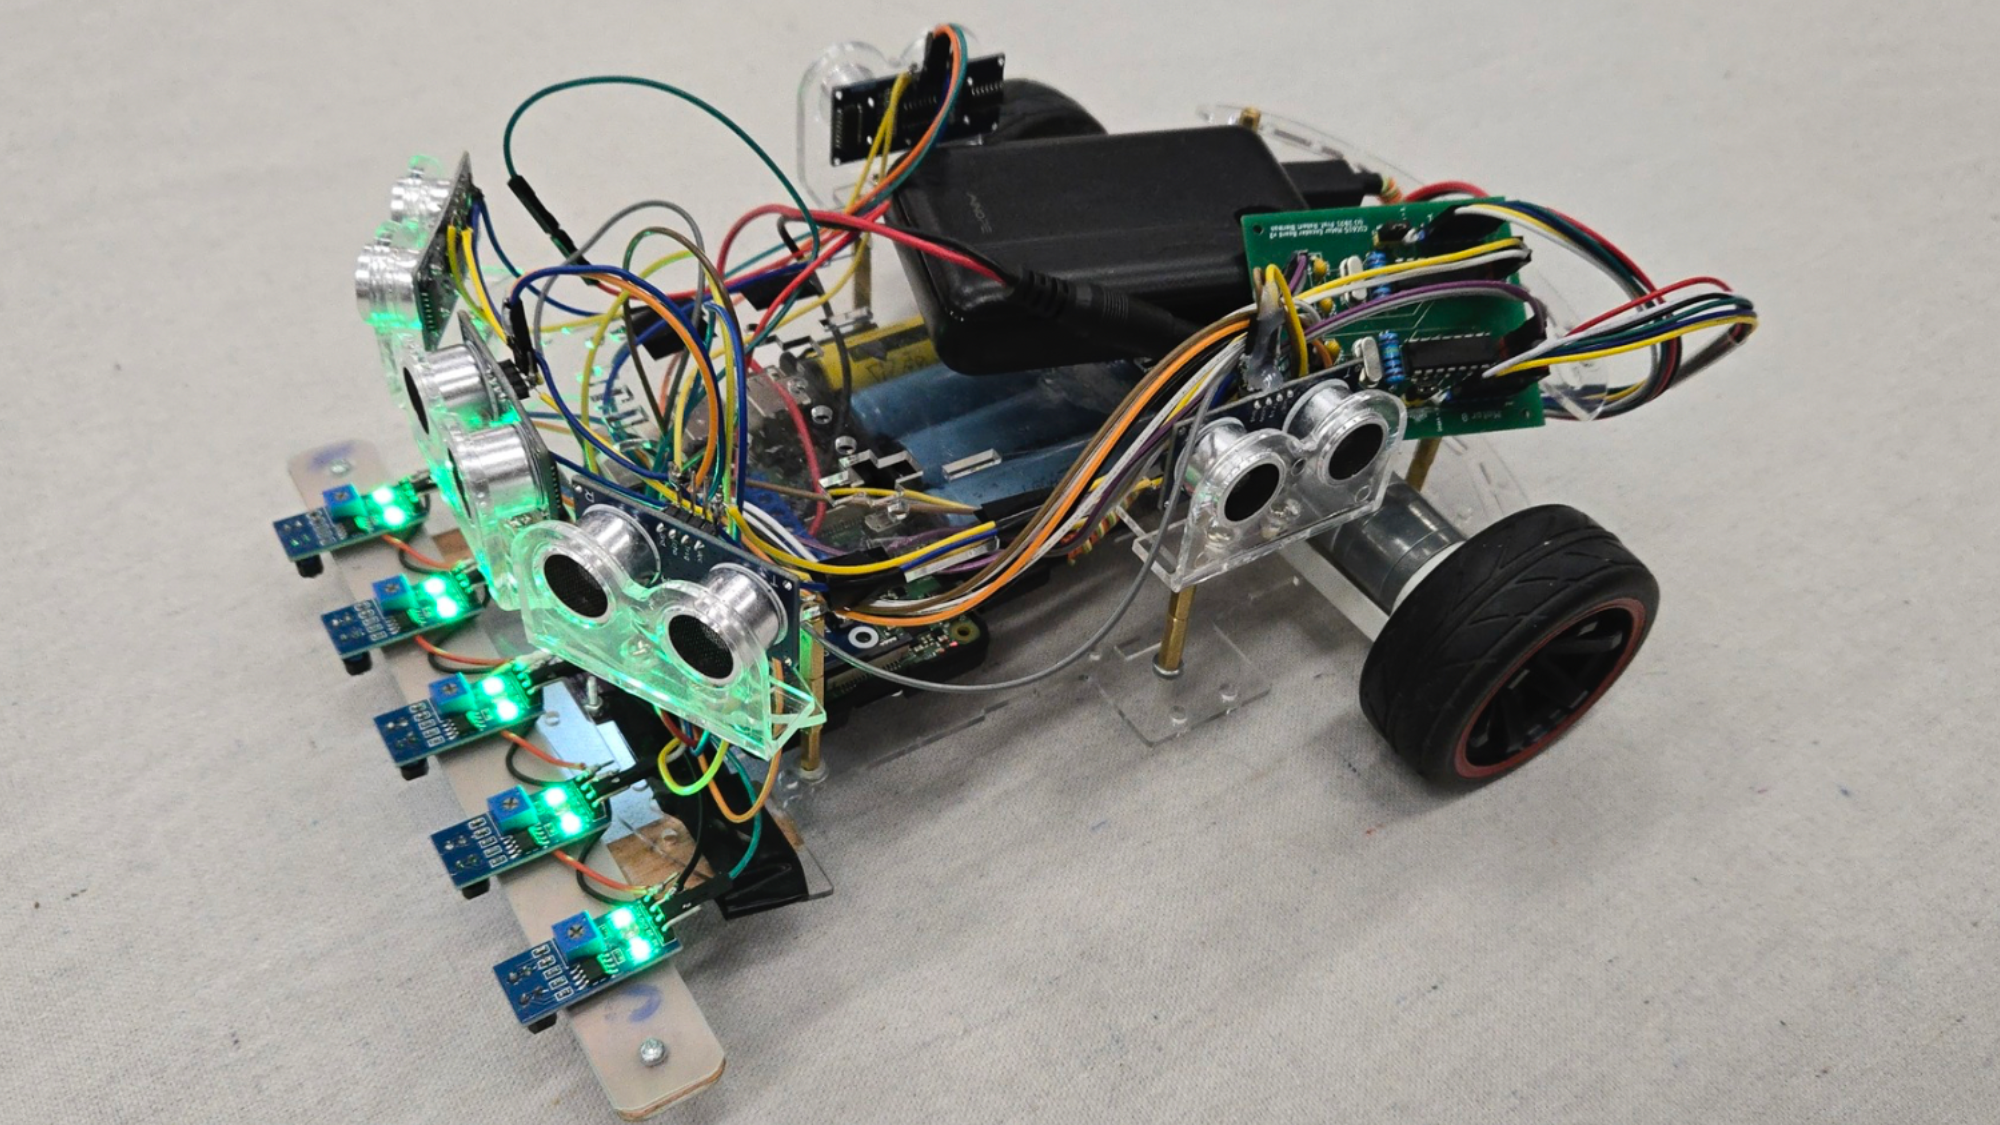
Project Gallery
Interested in This Project?
I'm always excited to discuss my projects and share insights about the development process. Feel free to reach out if you'd like to know more!